Product Structure: LIMO COBOT
Welcome to the Product Structure documentation for the LIMO COBOT platform — an integrated modular robotic system combining mobile autonomy, precision manipulation, and AI-powered perception.
Modular Components Breakdown
LIMO COBOT comprises the following key components:
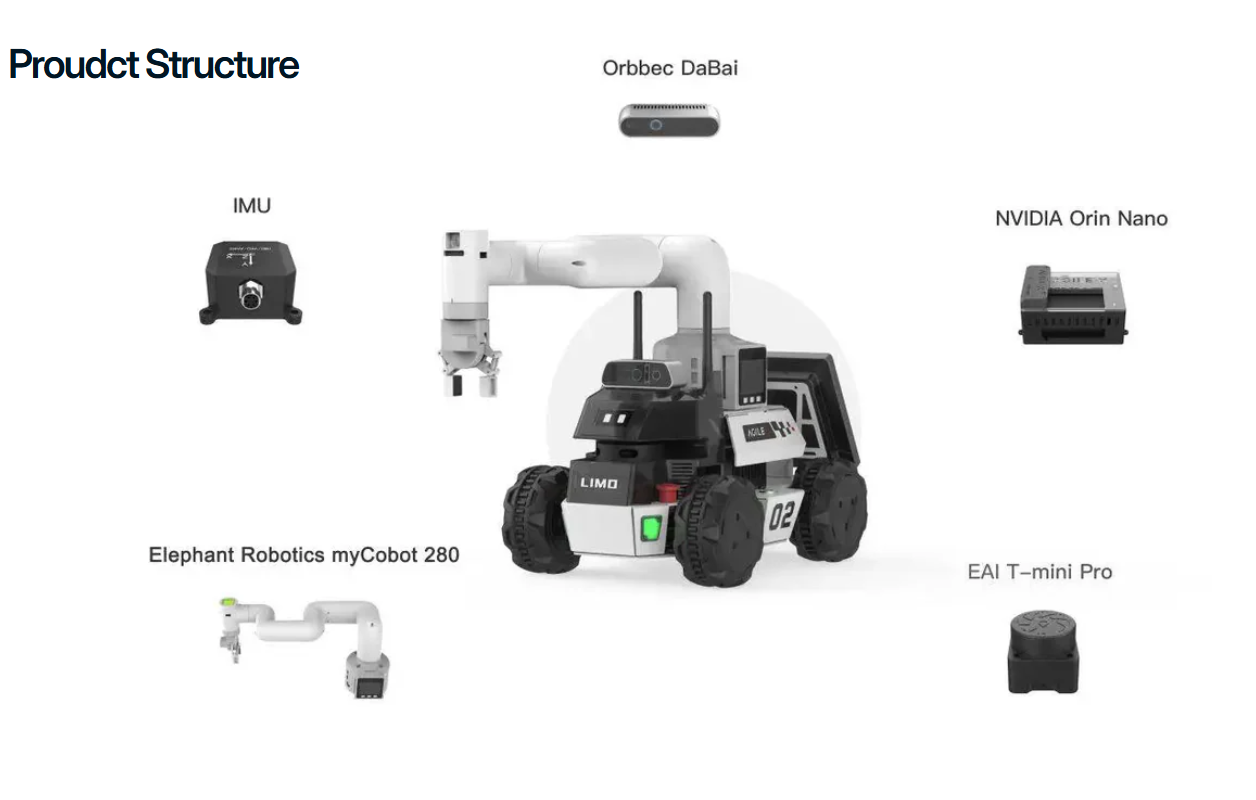
1. 🚗 Base Platform – LIMO (Mobile Robot Chassis)
- Manufacturer: AgileX Robotics
- Function: Mobile base with onboard compute, power, and sensor integrations
- Steering Modes:
- Differential
- Ackermann
- Omni-directional
- Tracked
- Wheel Type: Rubber all-terrain with independent suspension
- I/O Ports: USB, HDMI, Ethernet, CAN, UART
- Battery: 4S Li-ion with BMS (~40 min runtime)
- Model: LIMO PRO V2.0
- Application: Supports SLAM, navigation, autonomous driving algorithms
2. 🦾 Robotic Arm – Elephant Robotics myCobot 280 (6-DoF)
- Reach: 280 mm
- Payload: 250 g
- Repeatability: ±0.5 mm
- Weight: ~850 g
- Material: Aluminum alloy + ABS plastic
- Degrees of Freedom: 6
- Connectivity: USB / Serial
- Mount: Swappable end-effector (grippers, suction, tools)
- Use Case: Pick-and-place, human gestures, lab automation, object sorting
3. 🧠 Compute Module – NVIDIA Jetson Orin Nano
- CPU: ARM Cortex-A78AE
- GPU: Ampere architecture with 1024 CUDA cores
- AI Performance: Up to 40 TOPS
- Memory: 8 GB LPDDR5
- Interfaces: GPIO, I²C, UART, SPI, M.2
- OS: Ubuntu 20.04 with NVIDIA JetPack SDK
- Purpose: AI inference (YOLO, pose estimation), ROS2 nodes, sensor fusion
4. 🔎 Depth Camera – Orbbec DaBai
- Sensor Type: Stereo depth + RGB
- Depth Resolution: 1280×720
- RGB Resolution: 1920×1080
- Depth Range: Up to 8 meters
- Field of View: ~90°
- Interface: USB 3.0
- Applications: Obstacle avoidance, 3D mapping, hand tracking, human interaction
5. 🧭 Inertial Measurement Unit – IMU (e.g., MPU6050)
- Sensors:
- 3-Axis Gyroscope
- 3-Axis Accelerometer
- Purpose: Orientation, angular velocity, acceleration
- Usage: Pose estimation via sensor fusion (IMU + LiDAR + Odometry)
6. 🧠 LiDAR Sensor – EAI T-mini Pro
- Type: 2D 360° LiDAR Scanner
- Range: 0.1 – 12 meters
- FOV: 360°
- Scan Frequency: Up to 15 Hz
- Angular Resolution: ≤ 0.25°
- Interface: USB / UART
- Use Case: SLAM, obstacle detection, autonomous navigation
🔧 Physical Integration Layout
The components are compactly and logically mounted on the LIMO chassis:
- Robotic Arm: Top-front mounted — ensures optimal reachability
- Depth Camera (Orbbec DaBai): Front-mounted — eye-level for human-like perception
- LiDAR: Top-mounted — unobstructed 360° scanning
- IMU: Internally centered — stable motion tracking
- Jetson Orin Nano: Internally mounted with thermal design considerations
🧱 Capability Stack Overview
| Layer | Modules | Functional Role |
|---|---|---|
| Perception | Orbbec DaBai, LiDAR | Vision, mapping, depth sensing, SLAM |
| Intelligence | NVIDIA Orin Nano | AI computation, decision-making, sensor processing |
| Mobility | LIMO Chassis | Locomotion, terrain traversal, autonomous driving |
| Manipulation | myCobot 280 | Grasping, actuation, interaction |
| Sensing & Feedback | IMU, LiDAR | Pose estimation, obstacle awareness, localization |